PROJECT 01 · UNILEG
Simulation · 1:2 hardware in design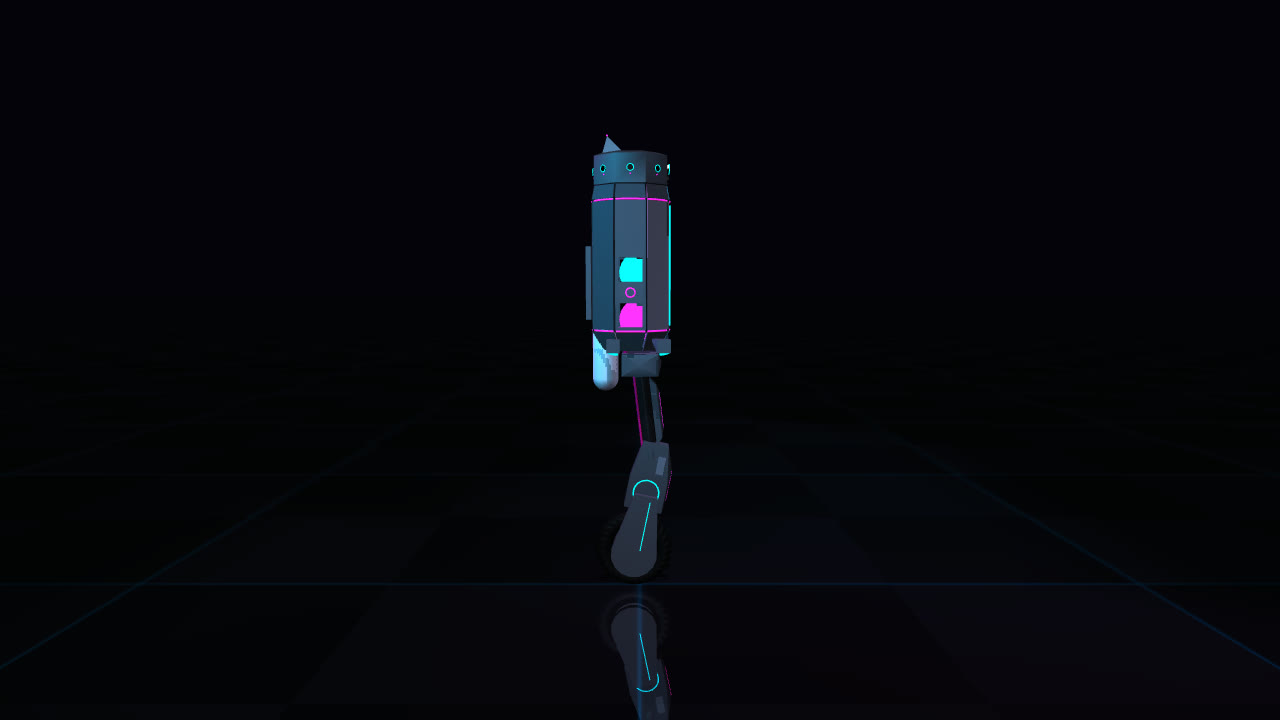
One wheel. One leg.
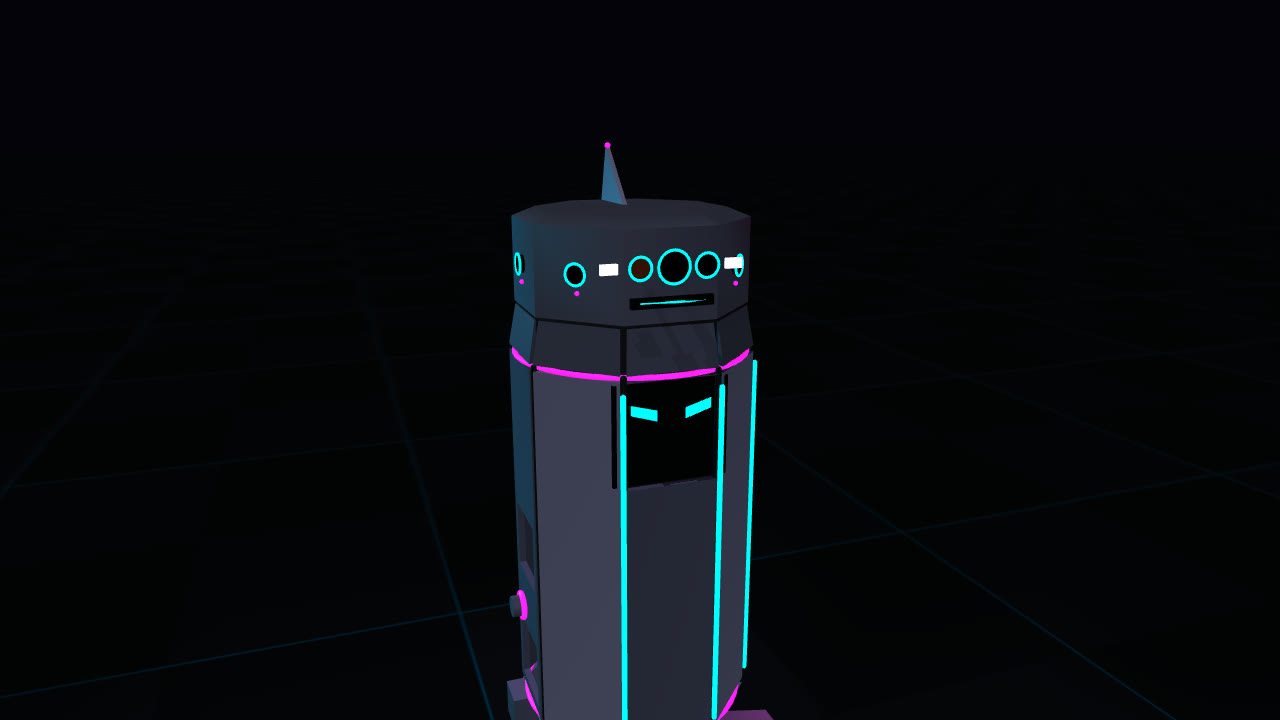
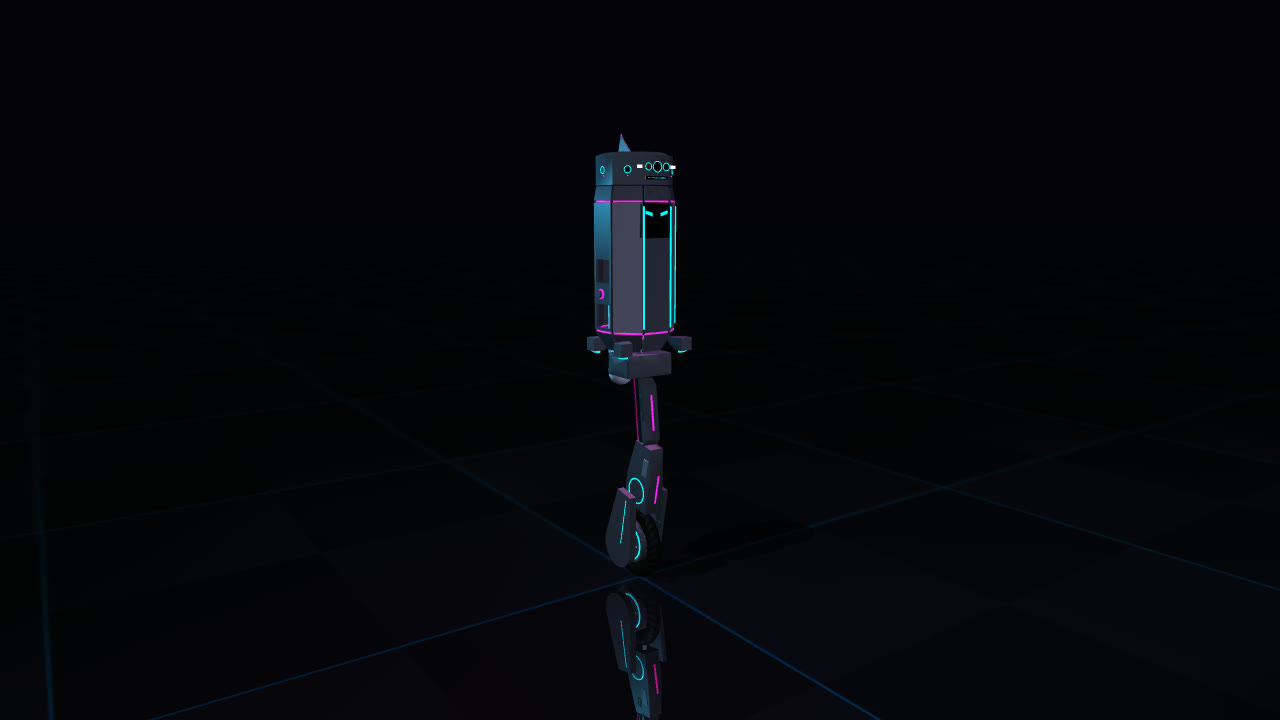
Unileg balances pitch on its wheel, holds roll with a pair of gyros in its torso and turns on a reaction wheel. The leg crouches, jumps and folds the robot into a hoop to roll. The current target is a 1:2 scale model built from hobby parts.
- Height
- 0.83 m
- Mass
- 2.53 kg
- Wheels
- 1
- Legs
- 1
HOW IT HOLDS UP
- Crowned wheel Balances pitch and drives.
- Leg Thigh, belt-driven knee with a parallel gas spring, shin. Hip pitch plus continuous hip yaw.
- Twin CMG Scissored control moment gyros in the torso hold roll, desaturated by leaning.
- Reaction wheel Yaw, for smooth turns in place and for flips.
- Sensor crown Eight-camera ring, thermal, lidar, floor ToF and a forward depth camera.